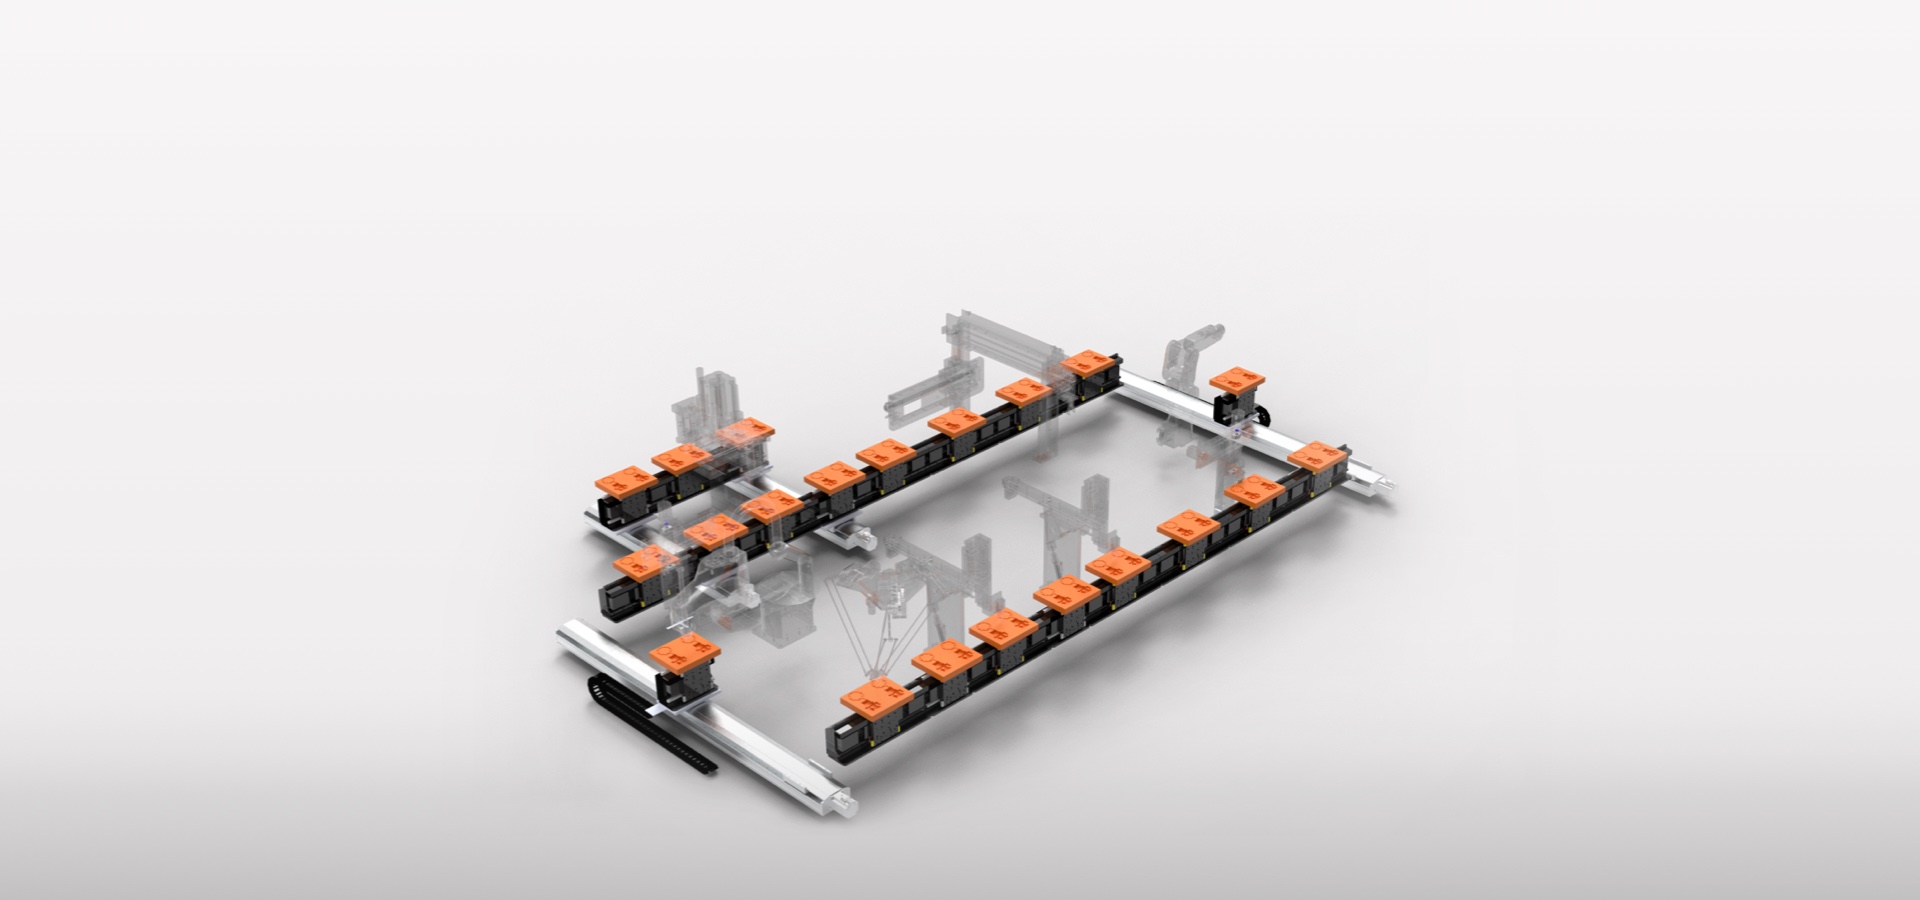
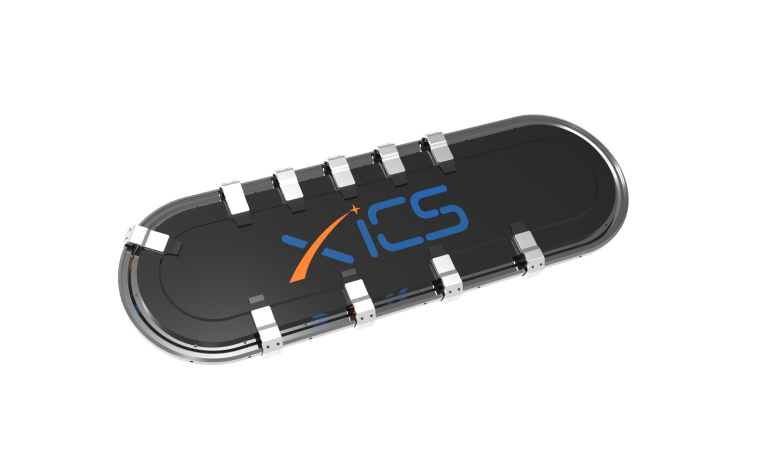
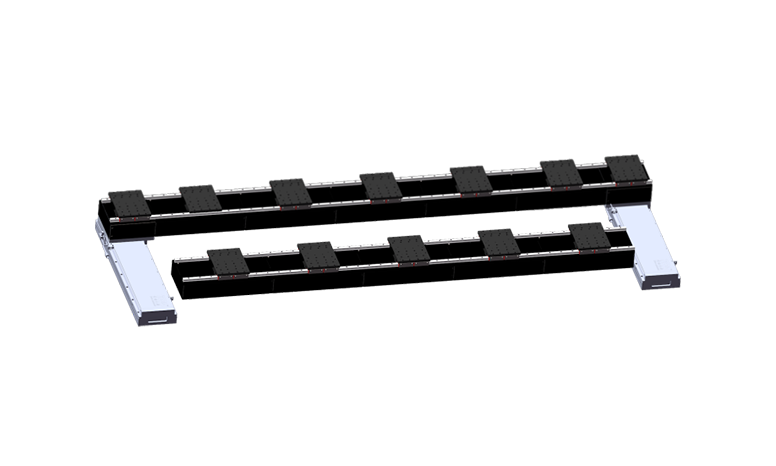
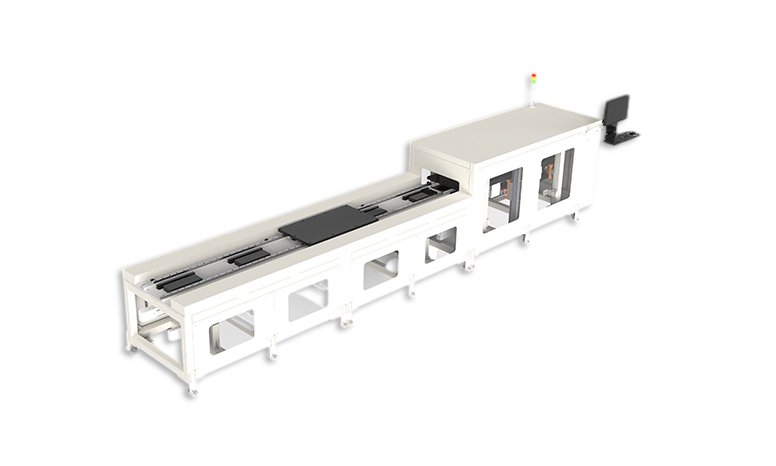
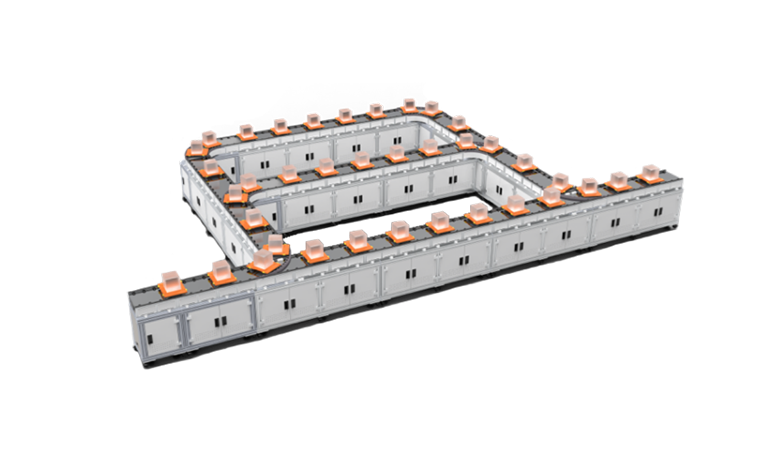
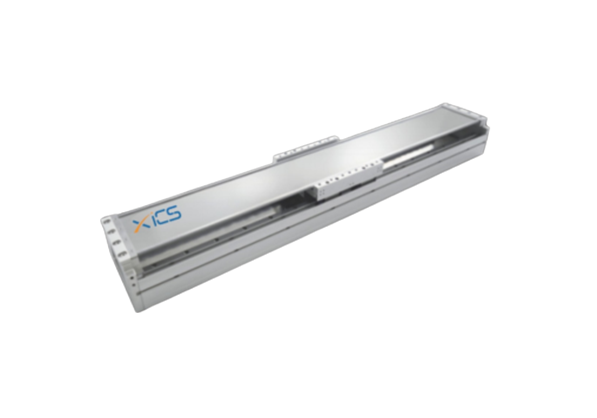
Supports dynamic tracking of sub-ids, can achieve load ferryover return, adopts modular design, has a simple installation method, and is suitable for medium and high load scenarios. In addition, it can be integrated with traditional conveying forms, and the overall cost is low.


Supports dynamic tracking of sub-ids, can achieve load ferryover return, adopts modular design, has a simple installation method, and is suitable for medium and high load scenarios. In addition, it can be integrated with traditional conveying forms, and the overall cost is low.
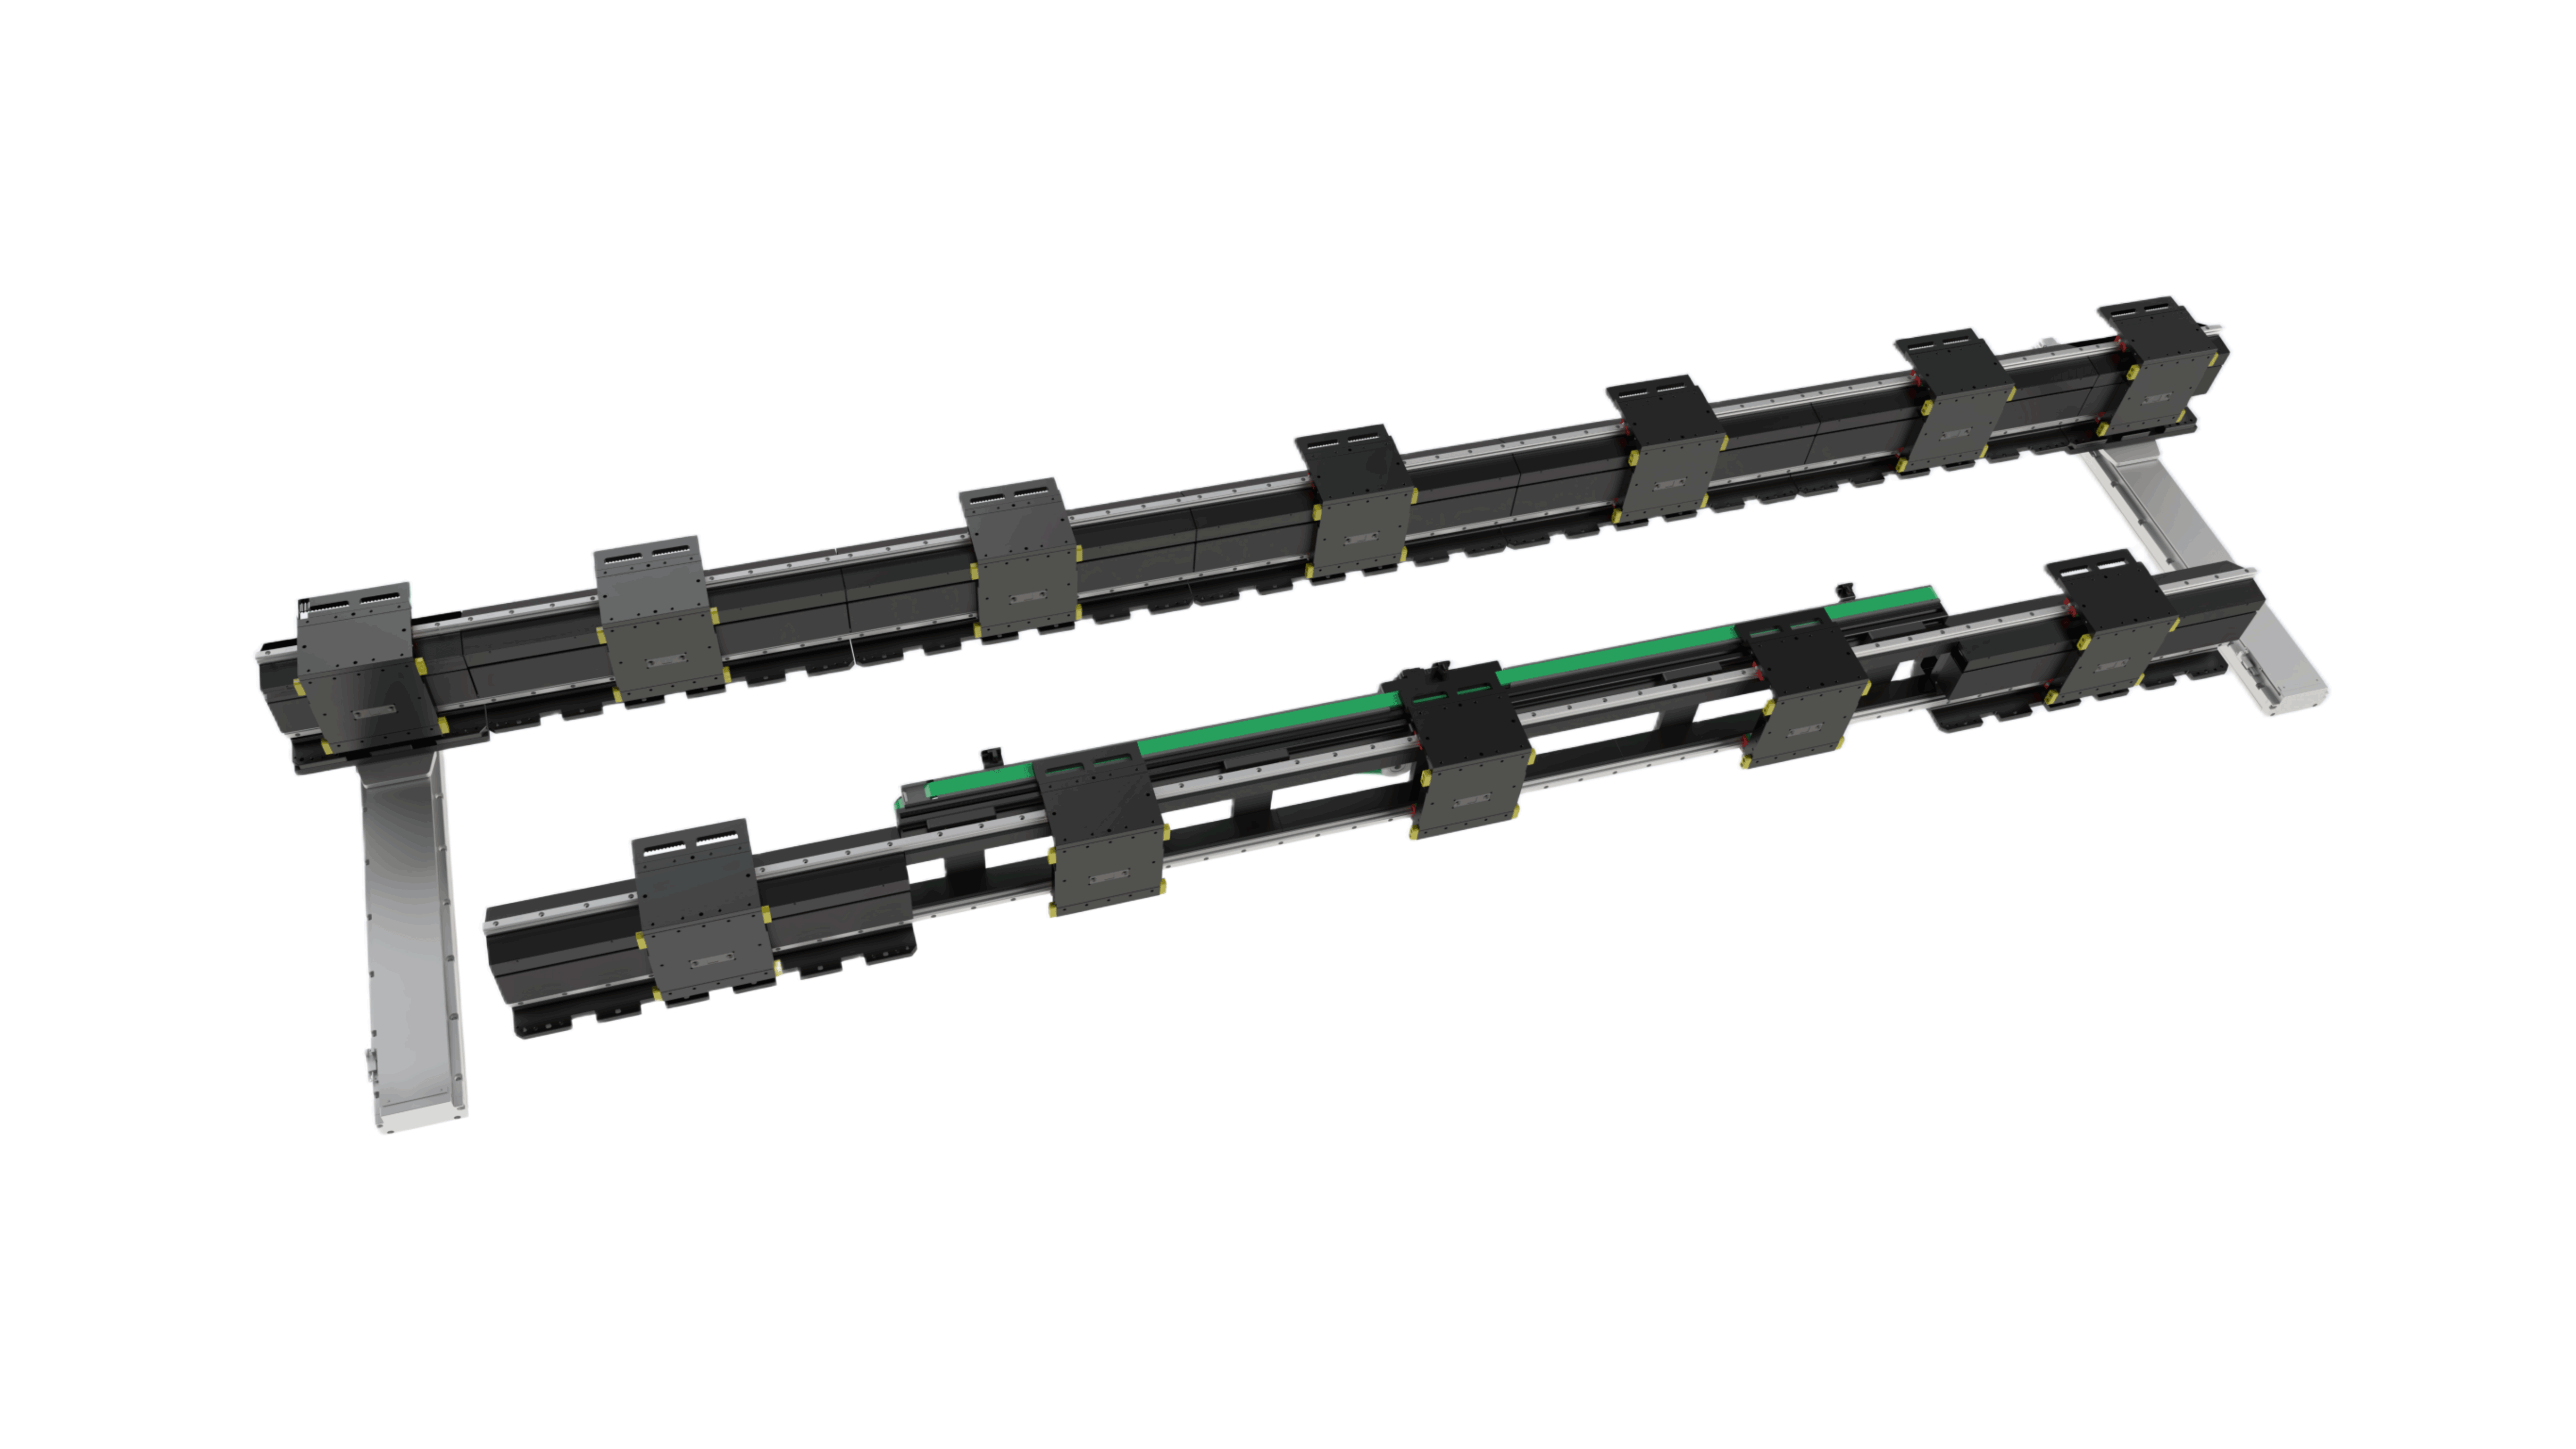
Supports dynamic tracking of sub-ids, can achieve load ferryover return, adopts modular design, has a simple installation method, and is suitable for medium and high load scenarios. In addition, it can be integrated with traditional conveying forms, and the overall cost is low.
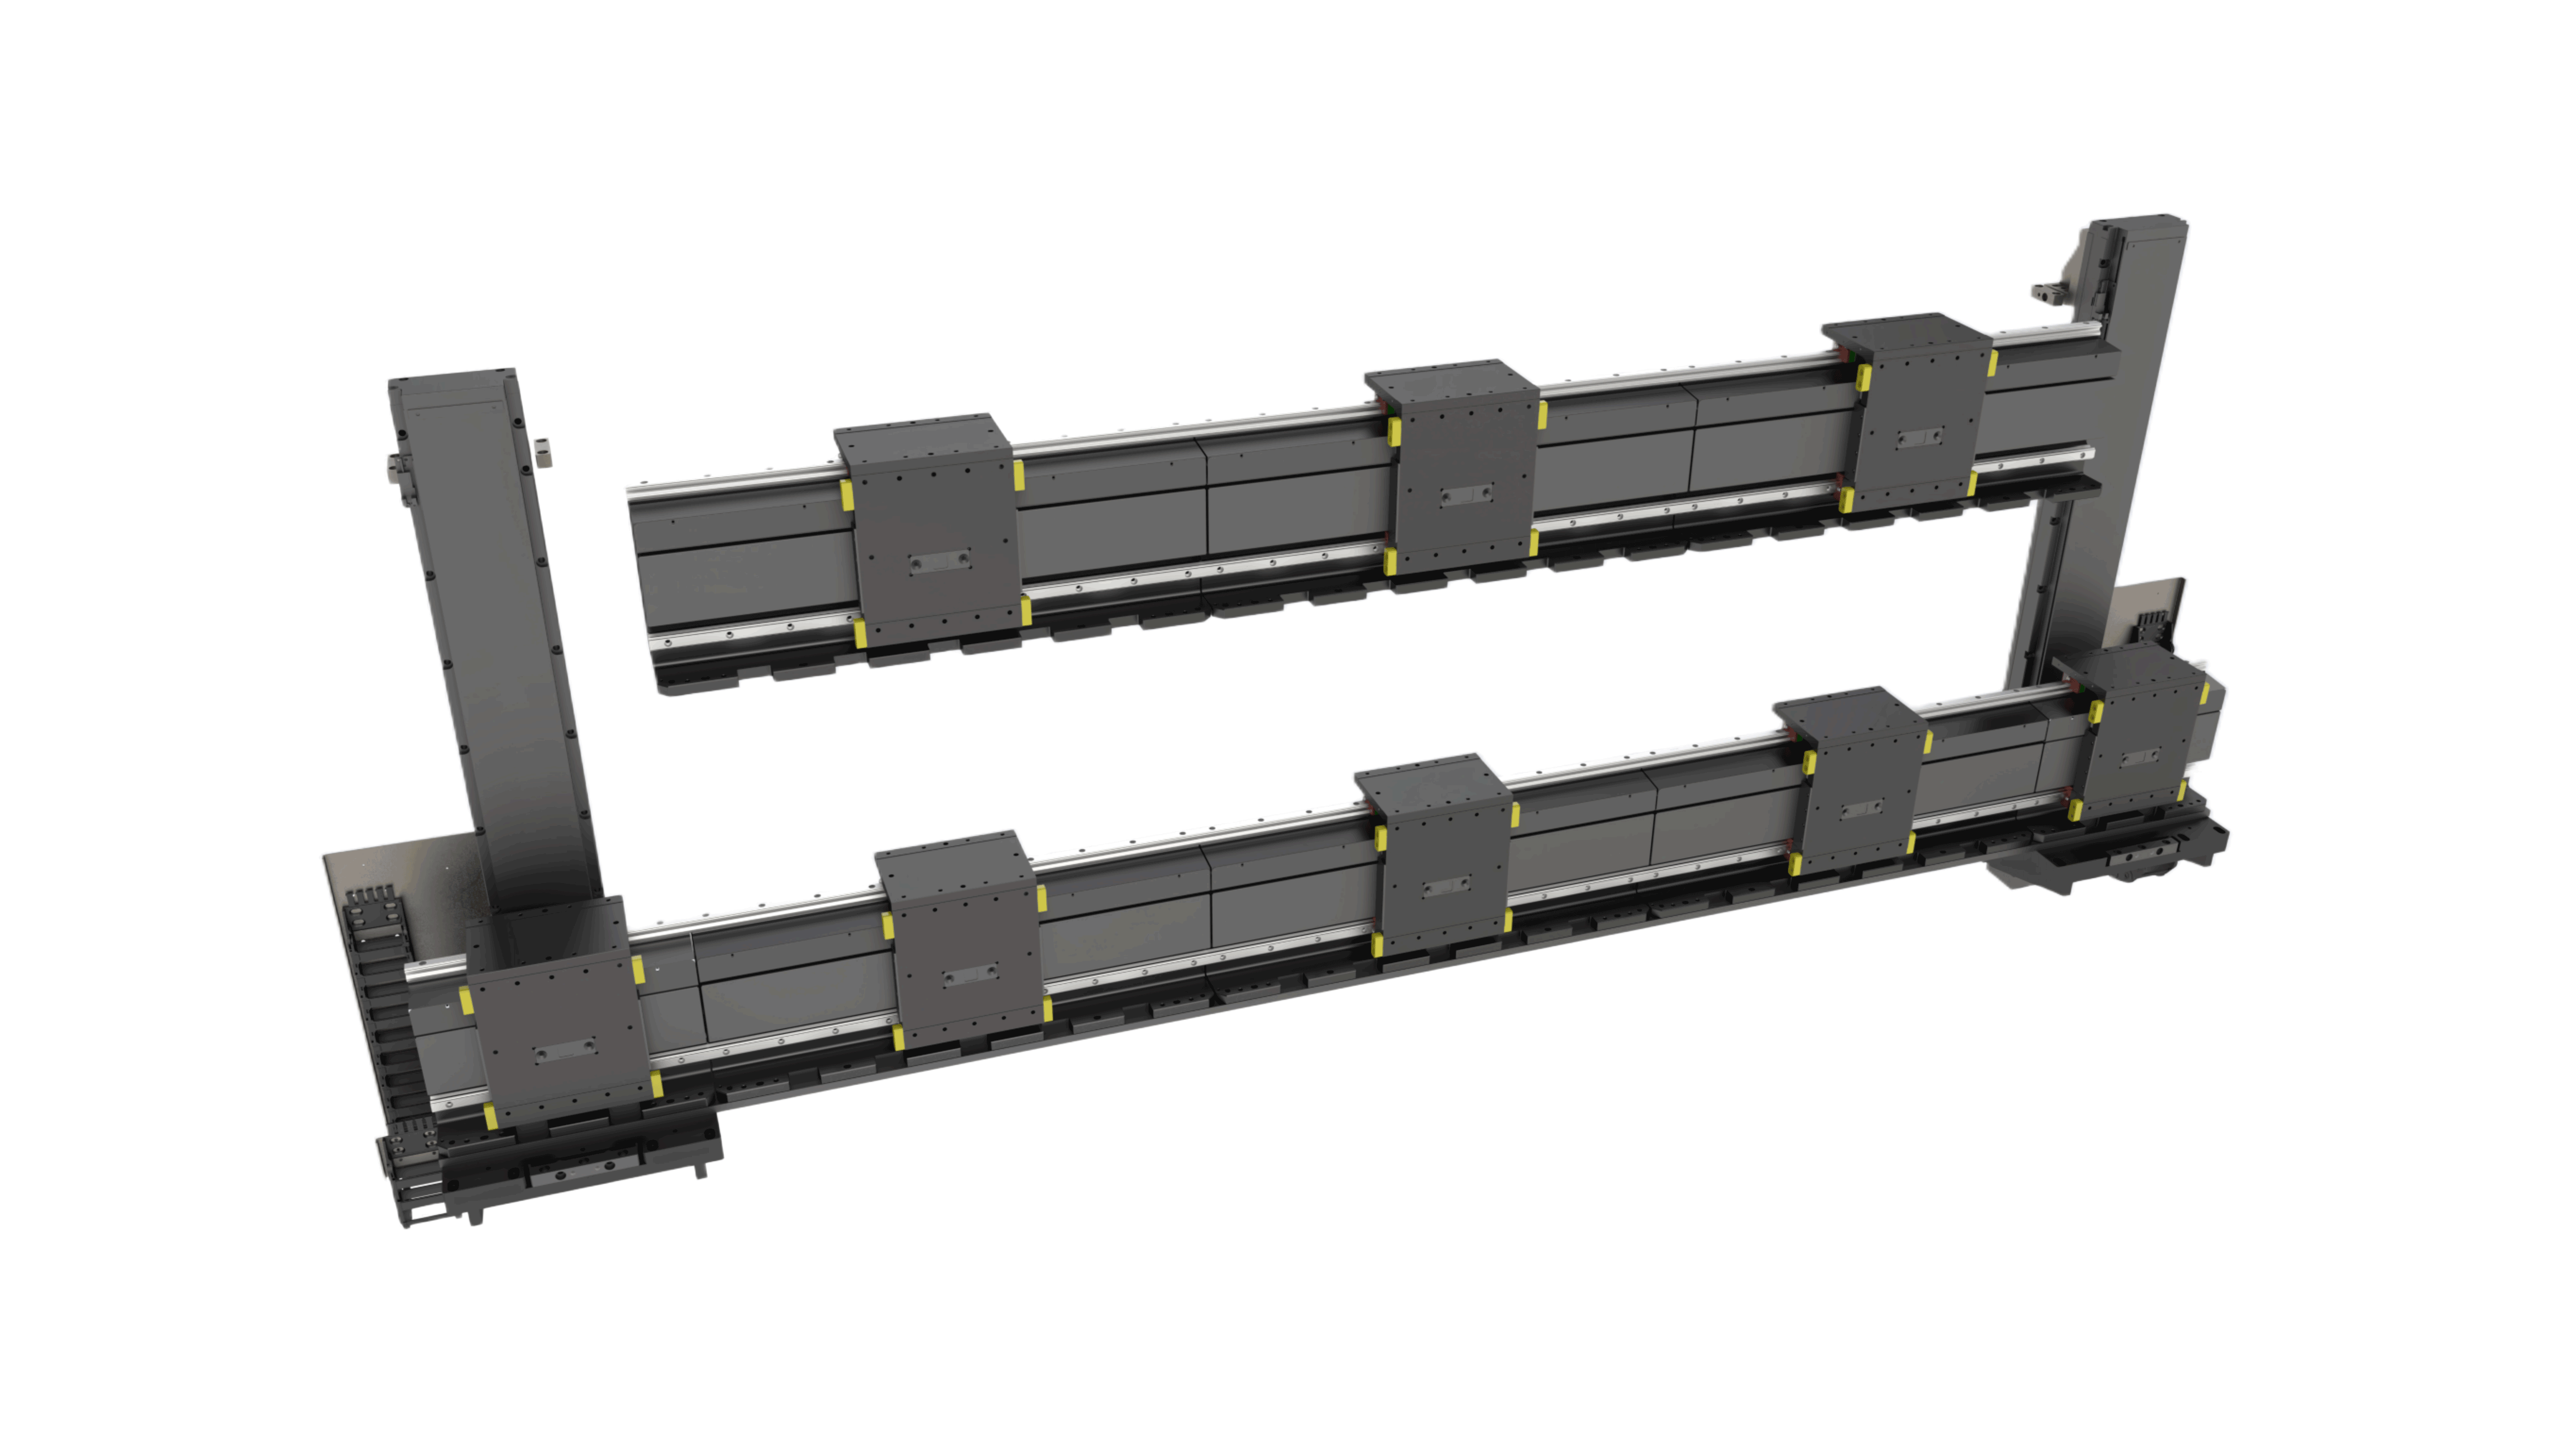
Supports dynamic tracking of sub-ids, can achieve load ferryover return, adopts modular design, has a simple installation method, and is suitable for medium and high load scenarios. In addition, it can be integrated with traditional conveying forms, and the overall cost is low.
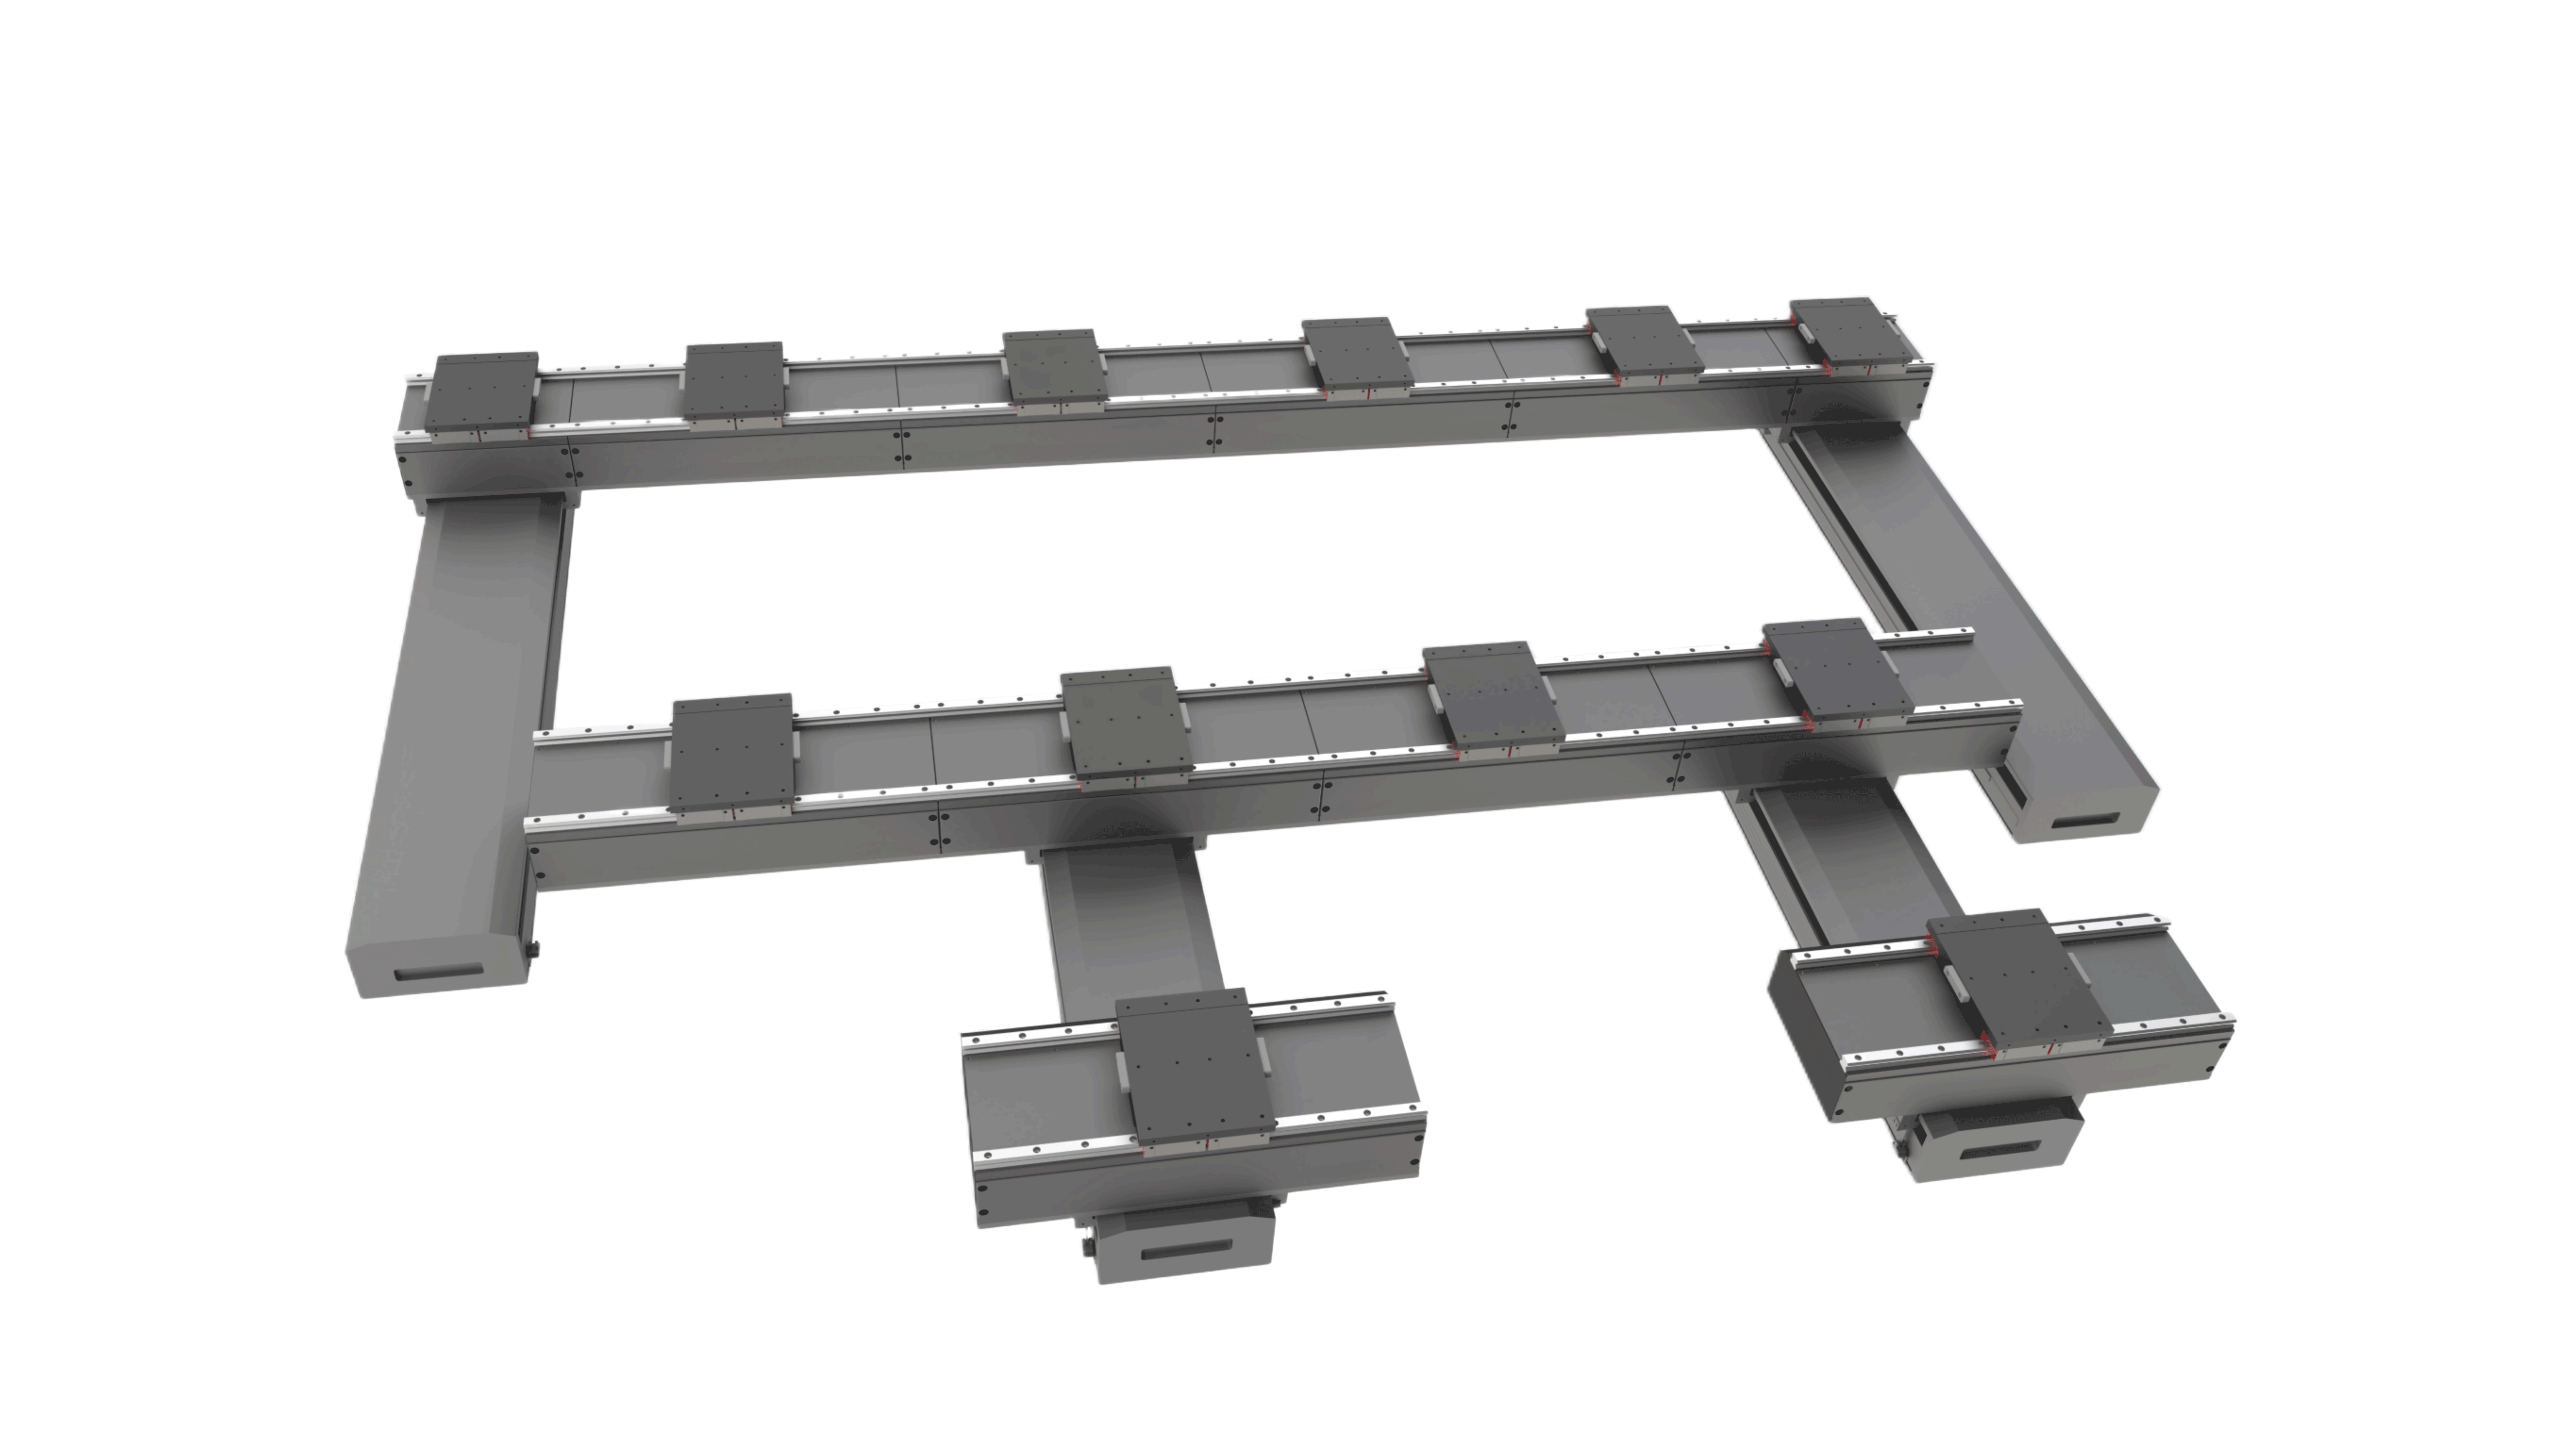
| Module structure | Vertical double-track | Horizontal double-track | ||
| Module length | 240/288/480/576 mm | |||
| Maximum thrust | 415 N | 650 N | ||
| Continuous thrust | 210 N | 328 N | ||
| Maximum load | 30 Kg | 40 Kg | ||
| Maximum speed | 2.5 m/s | |||
| Maximum acceleration | 2 g | |||
| Minimum center distance of the mover | 245/255/310mm | |||
| Repeat positioning accuracy | ±0.02 mm | |||
| Location detection | Absolute value position feedback | |||
| Communication interface | EtherCAT & Ethernet | |||
| Controller/Driver | XiCS-CH/ XiCS-DX | |||
| Controller power supply | 24VDC | |||
| Driver power supply | 55VDC | |||
 0512-57252888
 下载PDF